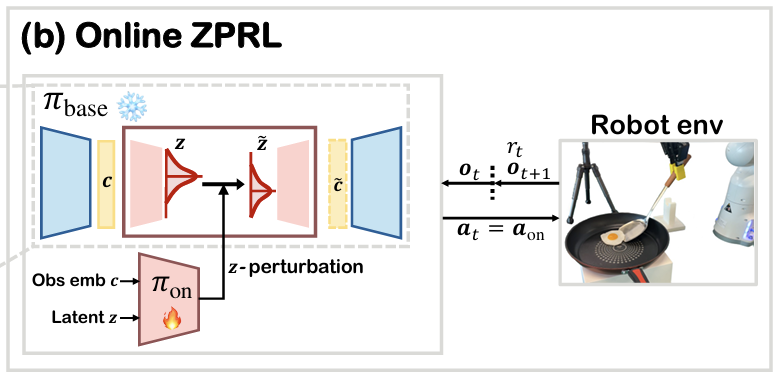
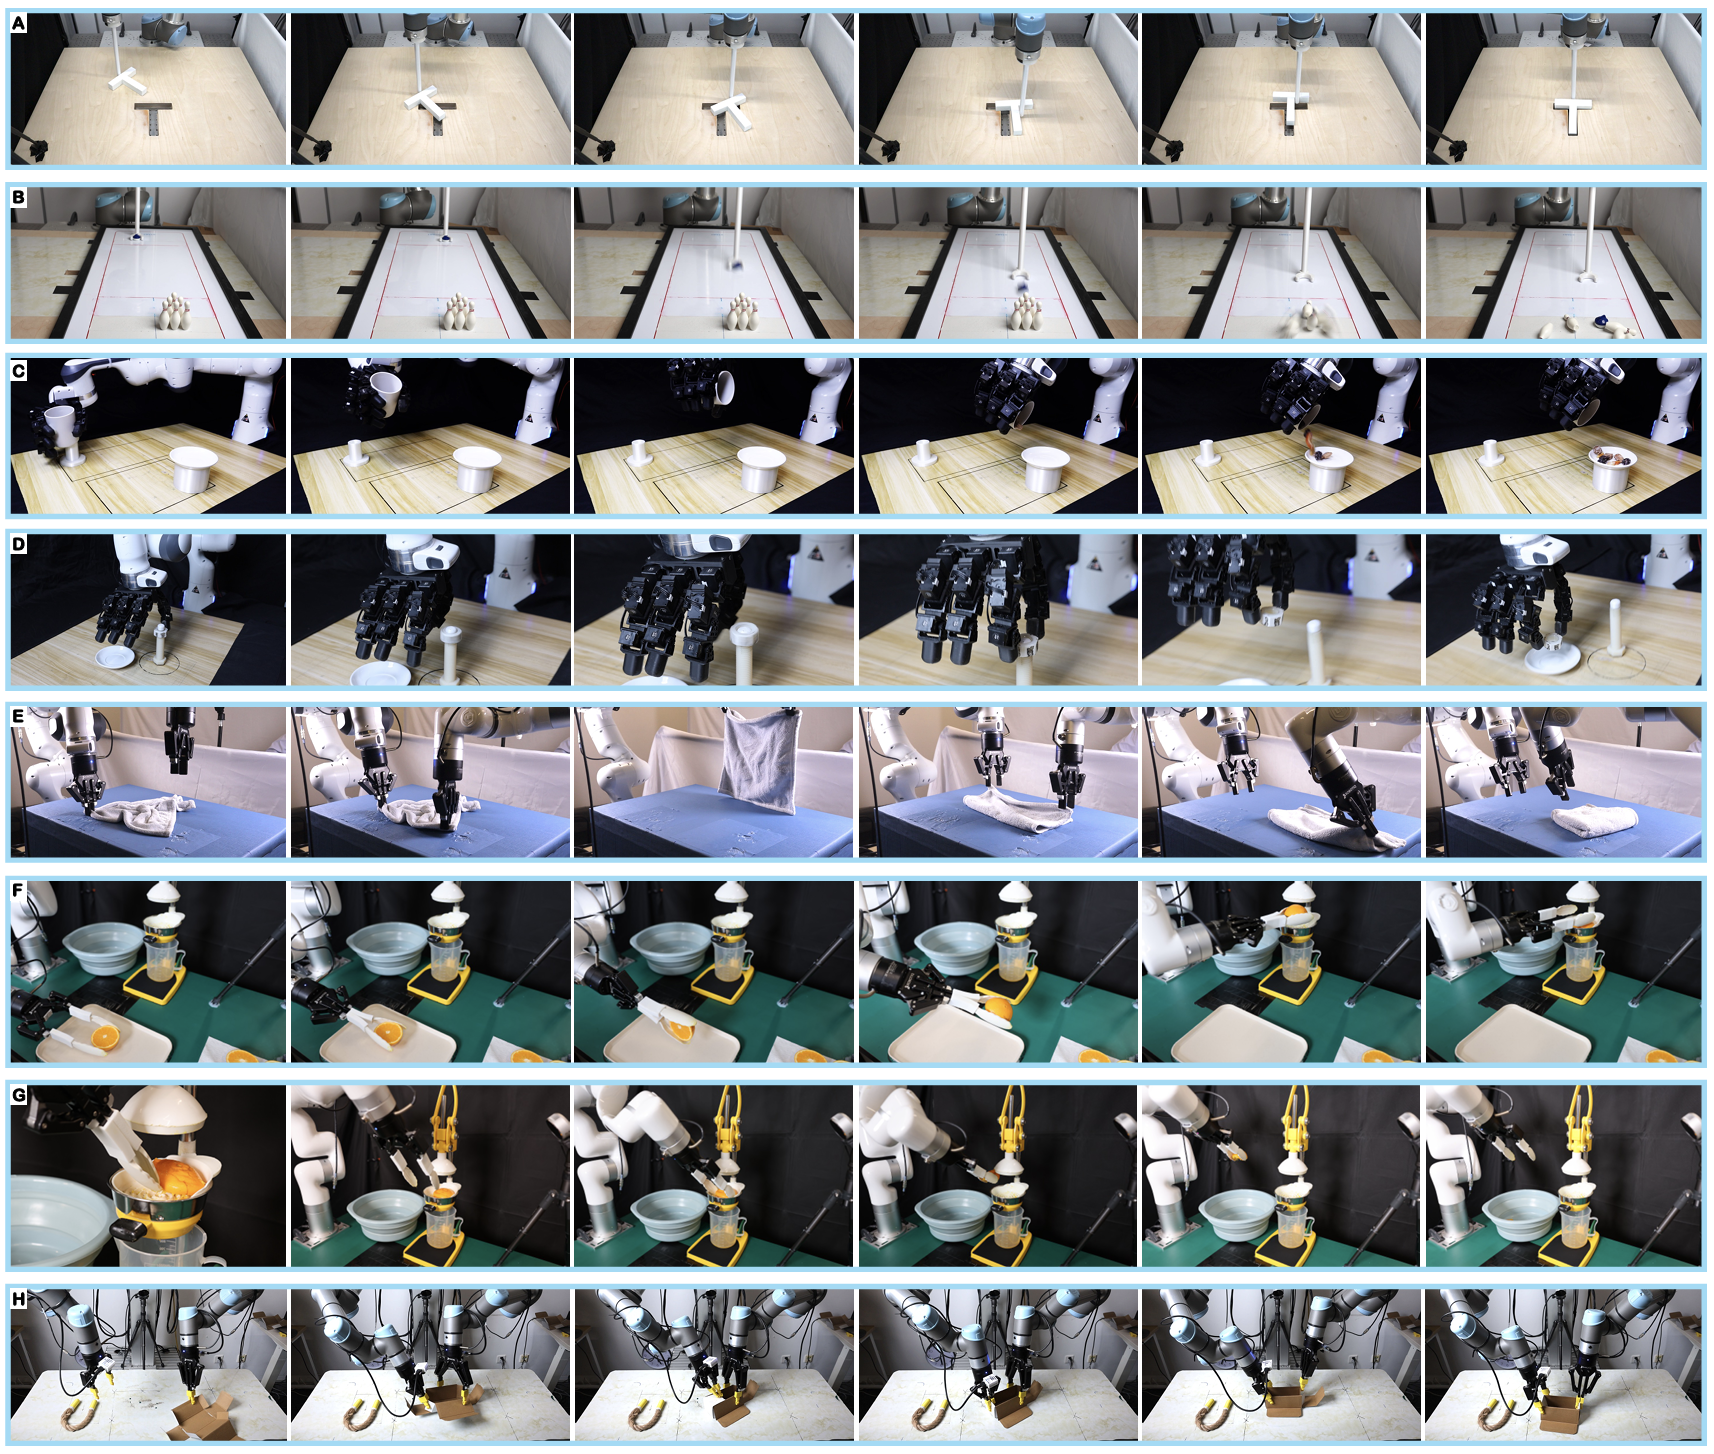
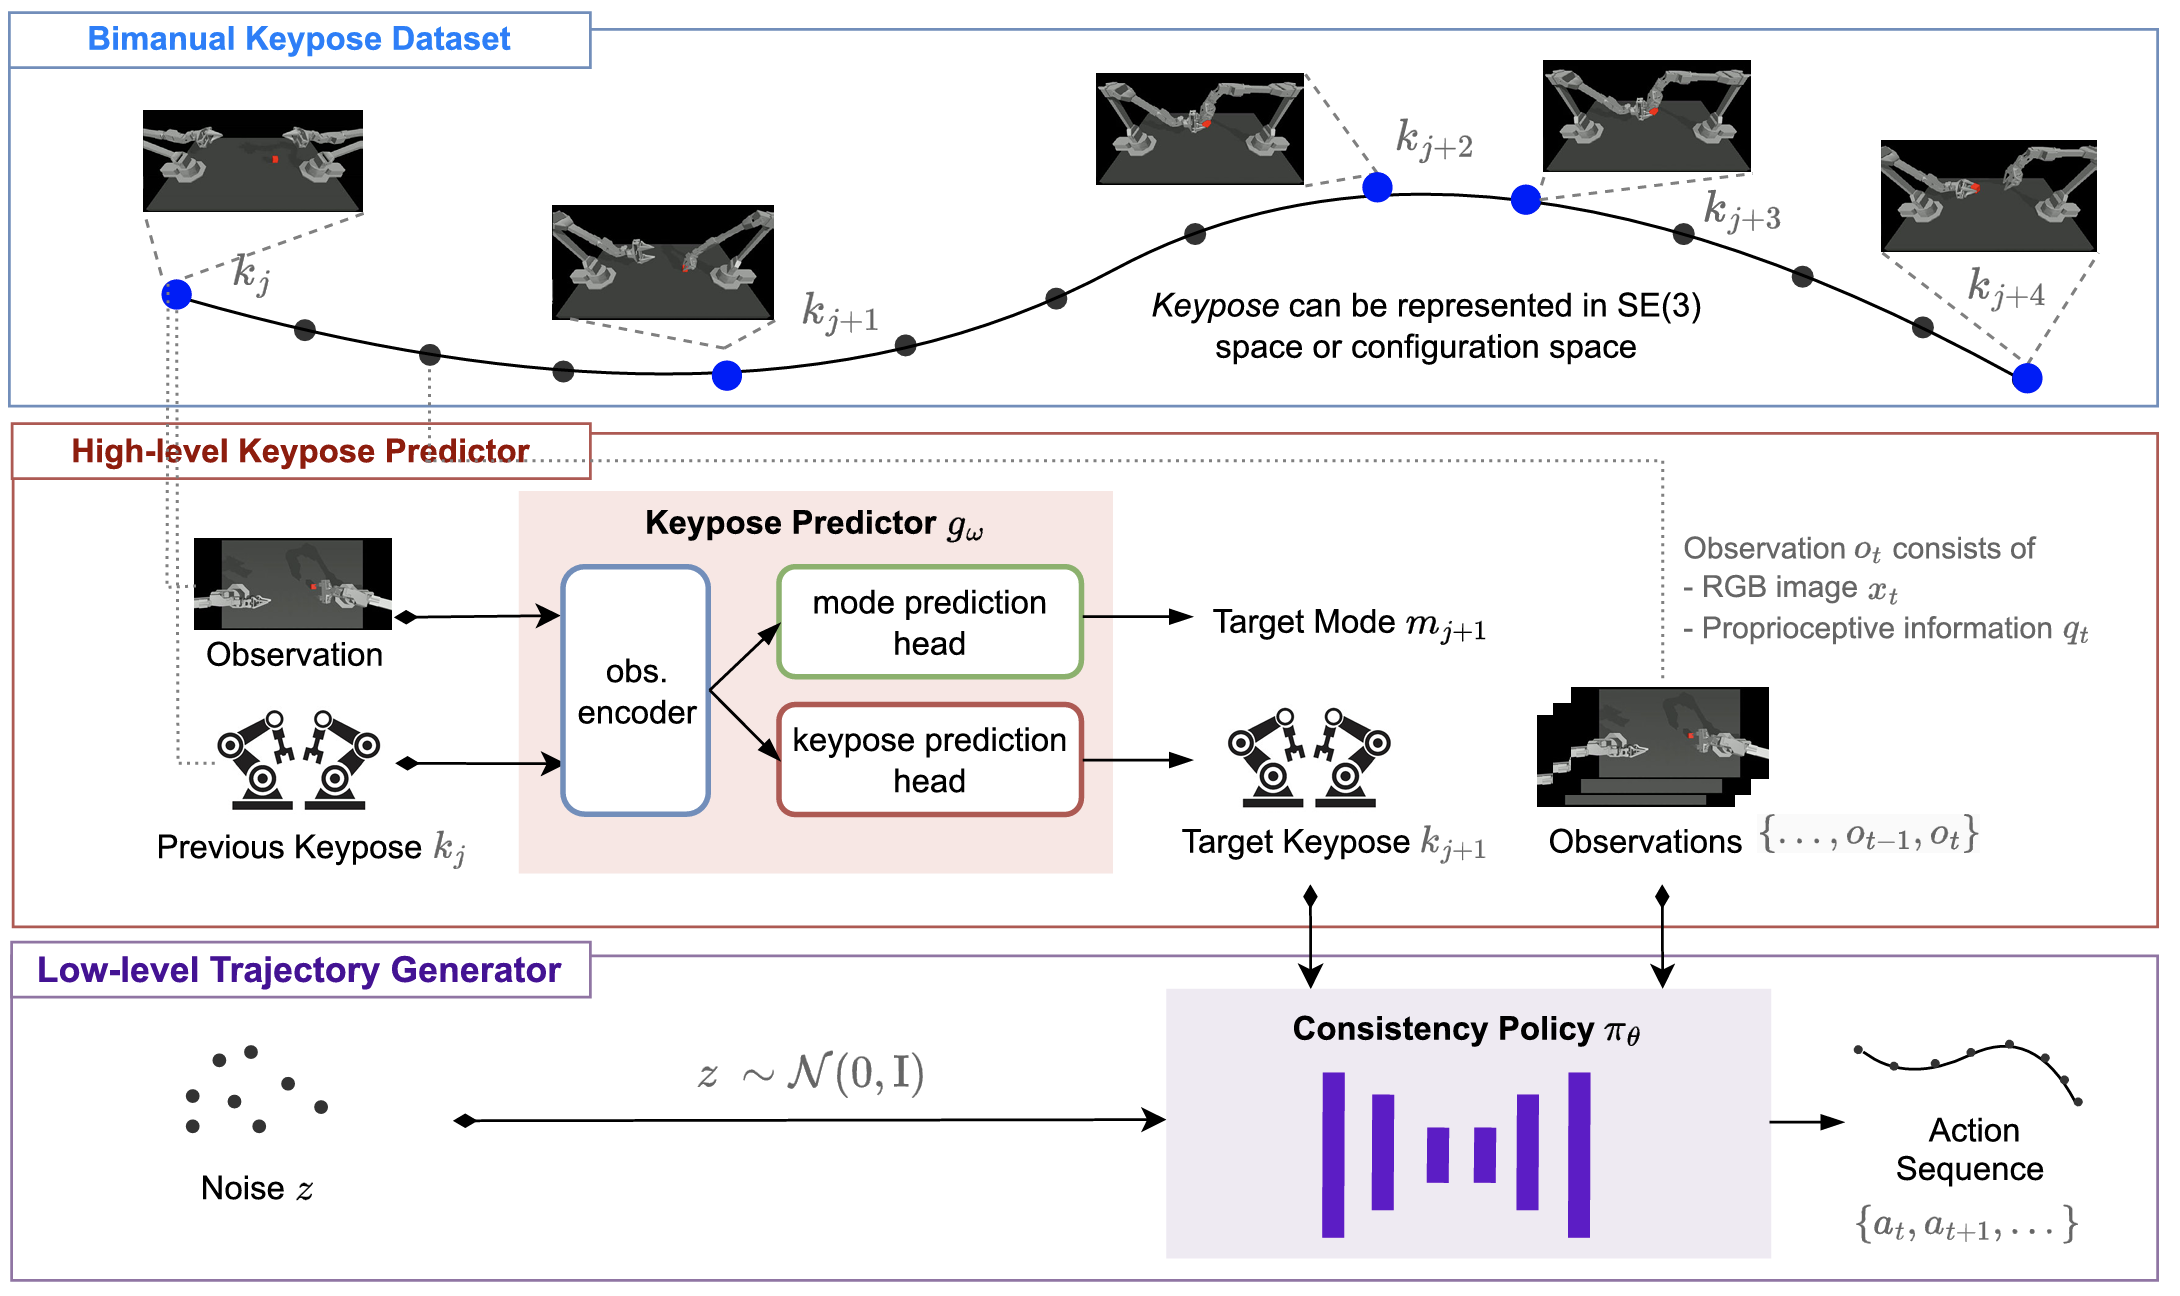
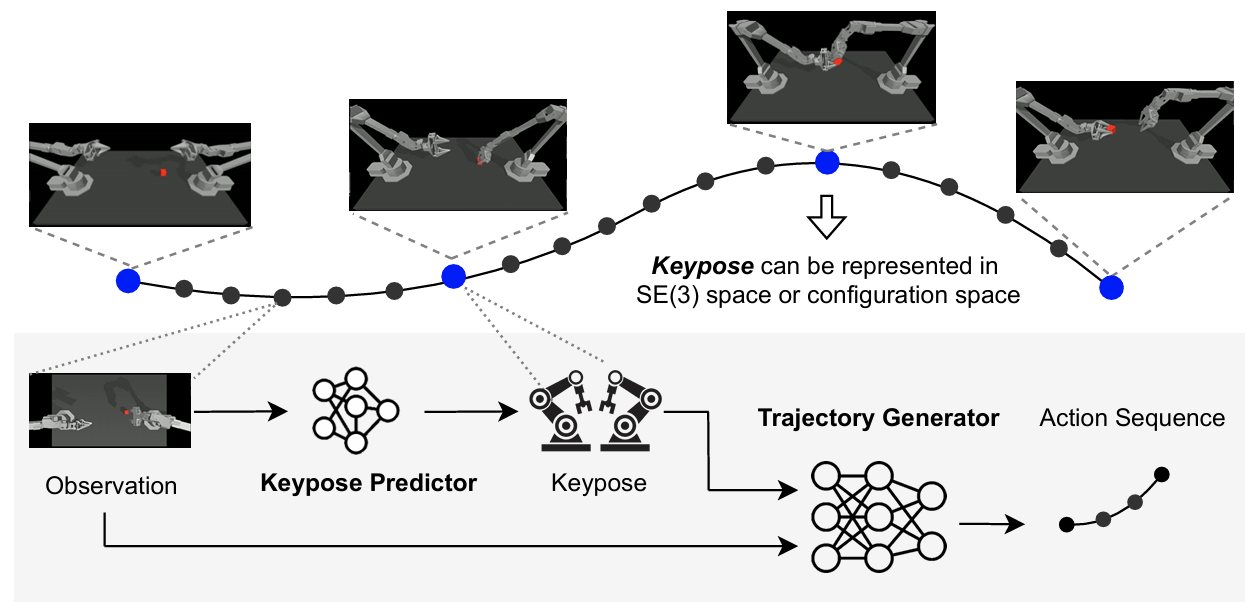
My research focuses on robot learning for manipulation, especially imitation learning and reinforcement learning. I am interested in improving learned robot policies through RL post-training.
I interned at Shanghai Qizhi Institute, working on RL post-training for imitation policies, and at Xiaomi Robotics in 2025, working on teleoperation with ViTai tactile sensors.
I received my M.S. (2023) and B.S. (2020) in Mechanical Engineering from Tsinghua University, advised by Prof. Shengbo Li. I also collaborated with Prof. Jianyu Chen on safe RL and optimal control.
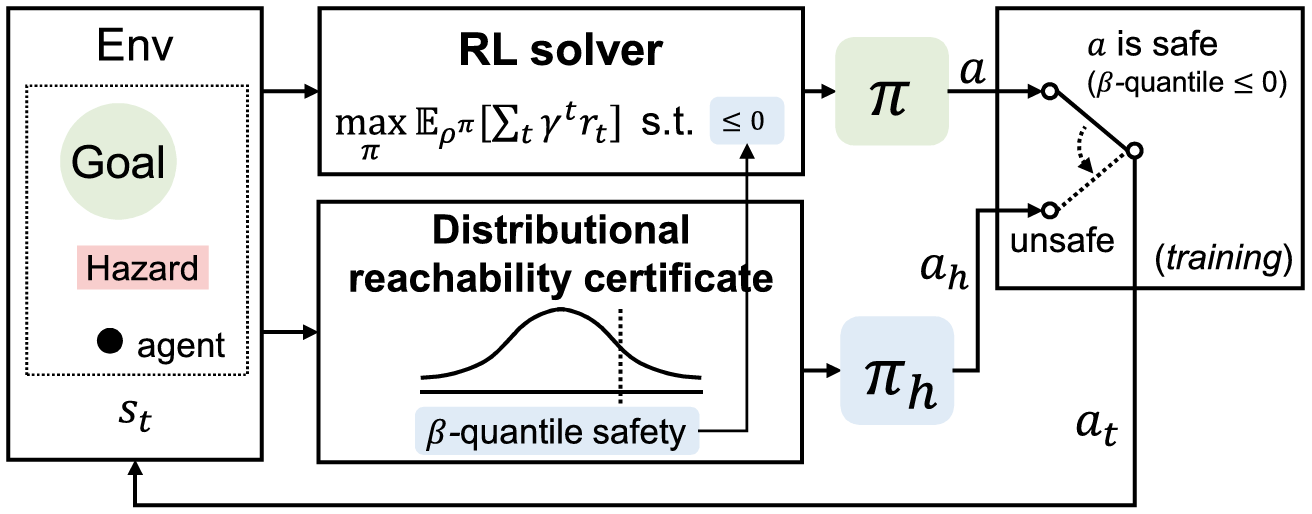
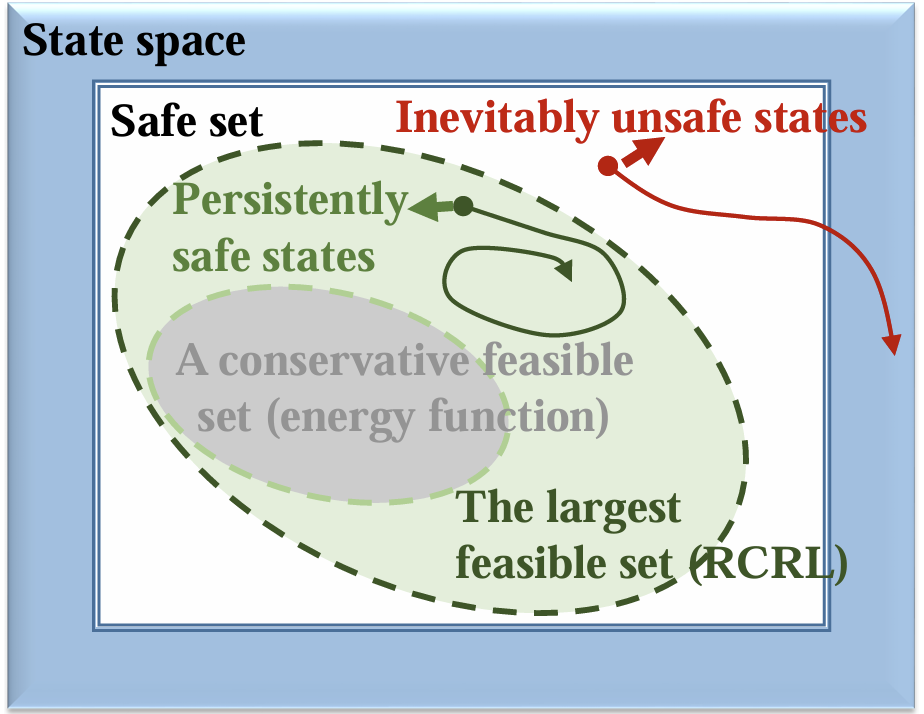
Hamilton–Jacobi reachability characterizes persistently safe states for constrained reinforcement learning.
Services
Reviewer
Journals: T-RO, T-II
Conferences: ICRA, IROS
Member, Tech Service Team of the Work-Study Program
Tsinghua University, 2020–2023
Excellent Team Member of the Month (x3) and of the Semester (x2); Outstanding Individual of the Work-Study Program in 2021 (top 10% in the university).